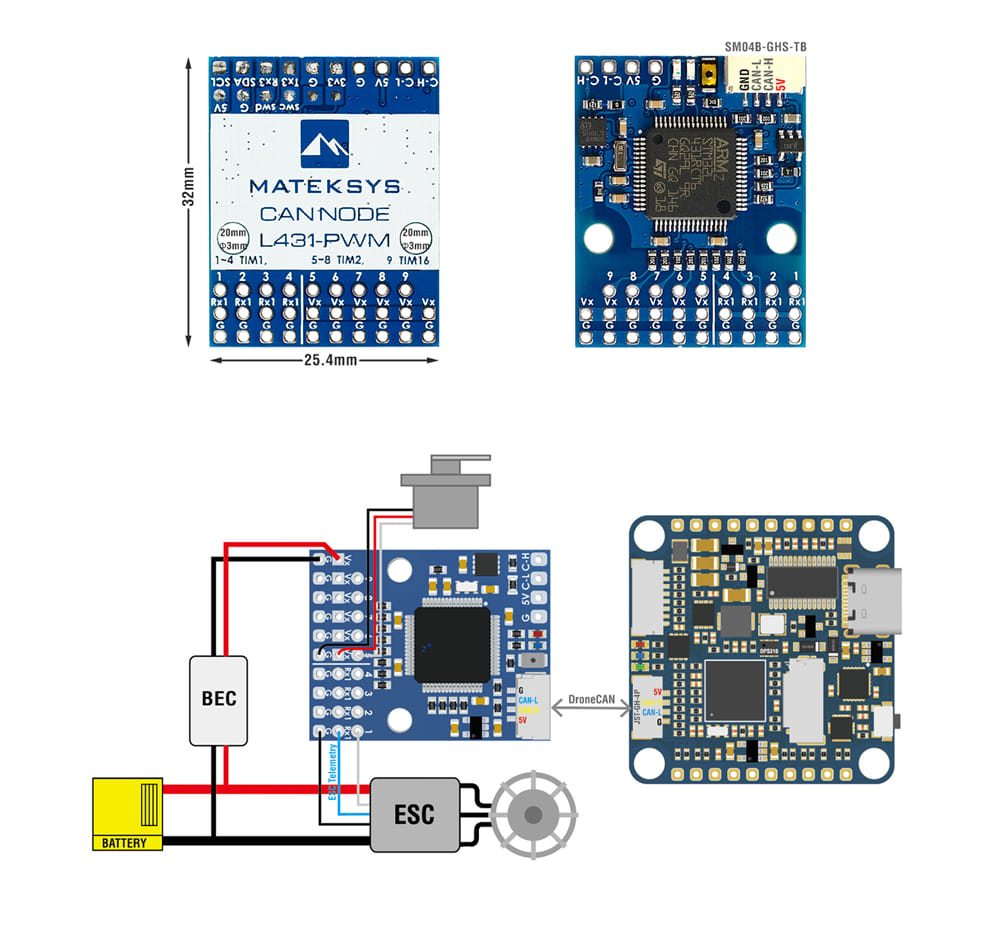
- ArudPilot AP_Periph 펌웨어를 기반으로 하는 어댑터 노드입니다.
- 주변장치를 DroneCAN 버스 주변 장치로 손쉽게 변환할 수 있습니다.
구성
CAN-L4-PWM 보드 1개
JST-GH-4P ~ JST-GH-4P 20cm 실리콘 와이어 1개
CAN-L4-PWM is an Adapter Node based on ArudPilot AP_Periph firmware.
Using this adapter to turn DShot capable ESCs into CAN ESCs, including full ESC telemetry. and turn PWM servos into CAN servos.
Specifications
MCU: STM32L431xC, 256KB Flash
1x CAN, DroneCAN Protocol
9x PWM outputs (8x Dshot)
1.5x UARTs
UART1, RX1
UART3, Tx3/ Rx3
ST debug, SWCLK & SWDIO
LED
Blue, Fast blinking, Booting
Blue, Slow blinking, working
Red, 3.3V indicator
Input voltage range: 4.5~5.5V @5V pad/pin
Power consumption: 30mA
Operating Temperatures: -20~80 °C
“Vx” pads are for powering servos via external BEC. “Vx” is not connected to other components on this board.
“Rx1” pads are for ESC Telemetry, DO NOT connect ESC BEC output to Rx1 pad.
Physical
1x JST-GH-4P(SM04B-GHS-TB) for CAN
Board Size: 32mm*25.4mm. 3.5g
Mounting: 20mm. Dia.3mm
3D file : CAN-L4-PWM_STEP.zip
Firmware
ArduPilot AP_Periph MatekL431-Dshot
Update via DroneCAN GUI Tool
Packing
1x CAN-L4-PWM board
1x JST-GH-4P to JST-GH-4P 20cm silicon wire
| SLCan Mode CAN1 > Parameters | Default Parameters |
| PWM | 1 | PA8 | TIM1_CH1 | OUT1_FUNCTION | 33 |
| 2 | PA9 | TIM1_CH2 | OUT2_FUNCTION | 34 |
| 3 | PA10 | TIM1_CH3 | OUT3_FUNCTION | 35 |
| 4 | PA11 | TIM1_CH4 | OUT4_FUNCTION | 36 |
| 5 | PA15 | TIM2_CH1 | OUT5_FUNCTION | 51 |
| 6 | PA2 | TIM2_CH3 | OUT6_FUNCTION | 52 |
| 7 | PA3 | TIM2_CH4 | OUT7_FUNCTION | 53 |
| 8 | PA1 | TIM2_CH2 | OUT8_FUNCTION | 54 |
| 9 | PA6 | TIM16_CH1
NO DMA | OUT9_FUNCTION | 55 |
| UART | RX1 | UART1 | Serial PORT 0 | ESC_TELEM_PORT | 0 |
| TX3 RX3 | UART3 | Serial PORT 2 | USER |
|
|
|
|
| ESC_PWM_TYPE | 7 |
|
|
|
| OUT_BLH_OTYPE | 6 |
|
|
|
| OUT_BLH_MAS | 15
|