Matek AP_Periph CAN RC Input Adapter, CAN-L4-RC
- ArudPilot AP_Periph 펌웨어를 기반으로 하는 어댑터 노드입니다.
- 주변장치를 DroneCAN 버스 주변 장치로 손쉽게 변환할 수 있습니다.
구성
CAN-L4-RC 보드 1개
JST-GH-4P ~ JST-GH-4P 20cm 실리콘 와이어 1개
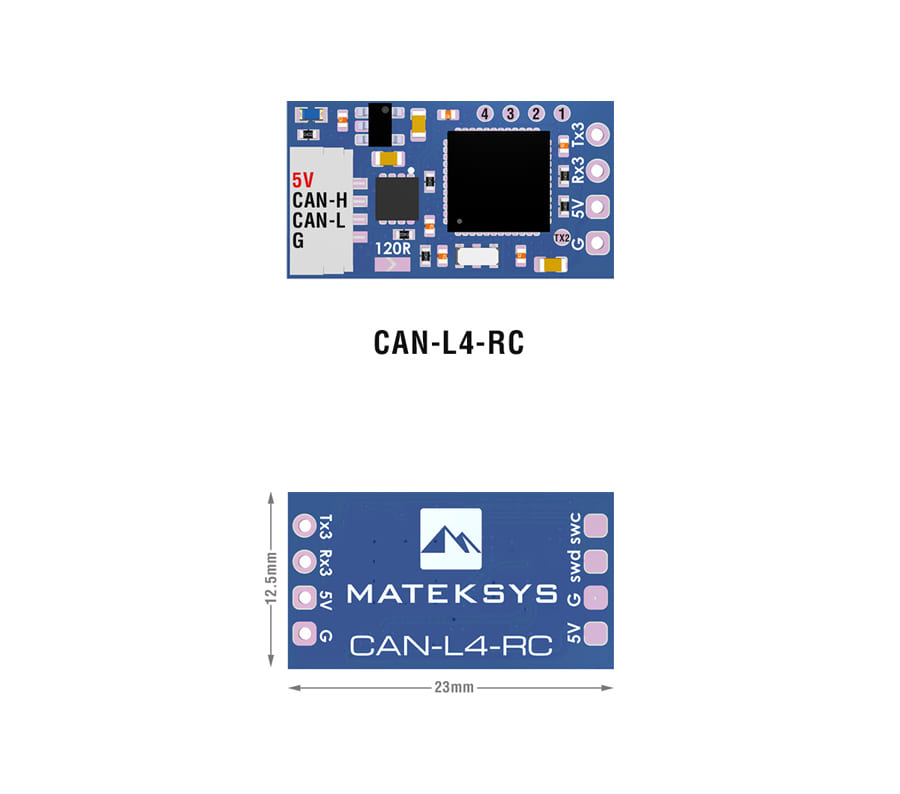 CAN-L4-RC is an Adapter Node based on ArudPilot AP_Periph firmware.
Using this adapter to turn Serial receiver into CAN receiver.
Specifications
MCU: STM32L431xC, 256KB Flash
1x CAN, DroneCAN Protocol
1x UART(UART3, Tx3/ Rx3)
ST debug, SWCLK & SWDIO
LED
Blue, Fast blinking, Booting
Blue, Slow blinking, working
Input voltage range: 4.5~5.5V @5V pad/pin
Power consumption: 10mA
Operating Temperatures: -40~85 °C
Physical
1x JST-GH-4P(SM04B-GHS-TB) for CAN
2.54mm pitch holes for UART3
Board Size: 23mm*12.5mm. 2.5g
3D file : CAN-L4-RC_STEP.zip
Firmware
ArduPilot AP_Periph MatekL431-RC
Update via DroneCAN GUI Tool
Packing
1x CAN-L4-RC board
1x JST-GH-4P to JST-GH-4P 20cm silicon wire
| CAN-L4-RC | Serial Receiver |
| CRSF | SBUS | F.Port | SRXL2 |
| | | | |
| Tx3 | RX | | F.Port | SRXL2 |
| Rx3 | TX | SBUS | | |
| 5V | 5V | 5V | 5V | 5V |
| G | GND | GND | GND | GND |
SLCan Mode CAN1 > Parameters
or DroneCAN GUI > Node Properties
RC1_PORT_OPTIONS | 0 default | 3 | 7 | 4 |
Tips
Supported by ArduPilot 4.5 or newer.
Receiver telemetry has not been implemented over DroneCAN
If the CAN wires are too long, bridge the “120R” jumper.
PWM 1~4 applications and setup, pls refer CAN-L-PWM page.
CAN-L4-RC board can also be flashed with MatekL431-GPS firmware to convert serial GPS into CAN GPS.