구성
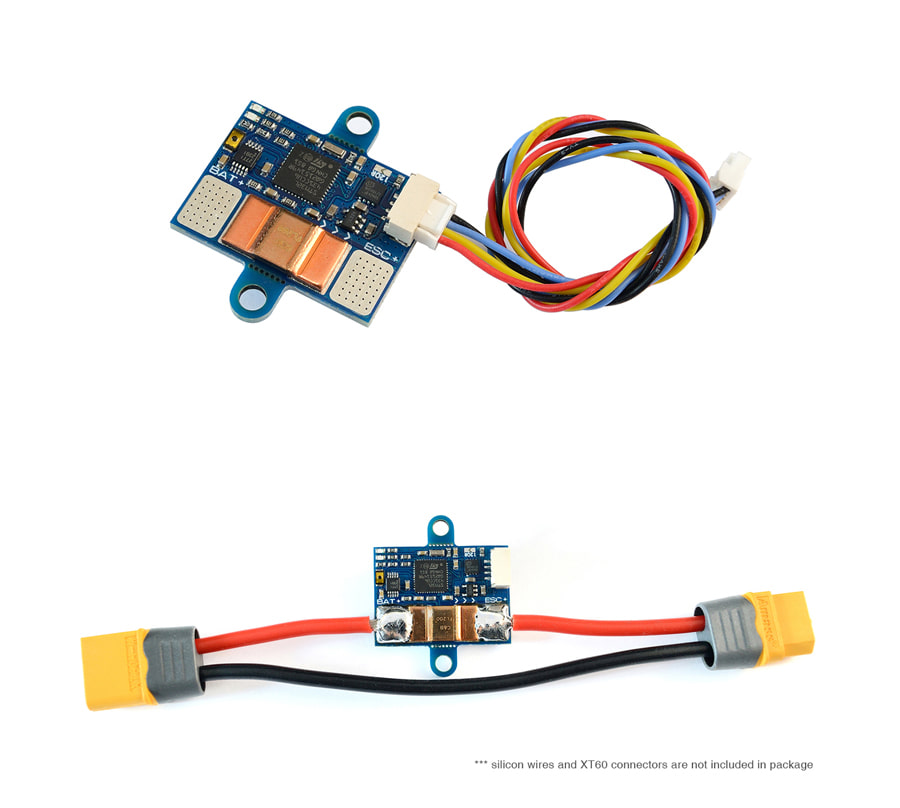
CAN-L4-BM 보드 1개
JST-GH-4P ~ JST-GH-4P 20cm 실리콘 와이어 1개
Due to limitations by AP_Periph firmware, the fw AP_Periph V1.7.0 and older do not support current readings greater than 90A.
You can update the fw to latest. then set AP_Periph parameters BATT_MAX_AMPS = 204.8 and BATT_SHUNT = 0.0002.
https://github.com/ArduPilot/ardupilot/pull/26465
CAN-L4-BM is a ultra-precise digital power monitor based on TI INA239 & ArudPilot AP_Periph firmware.
The resistance of this conductive path is 200 μΩ typical, providing low power loss in the application.
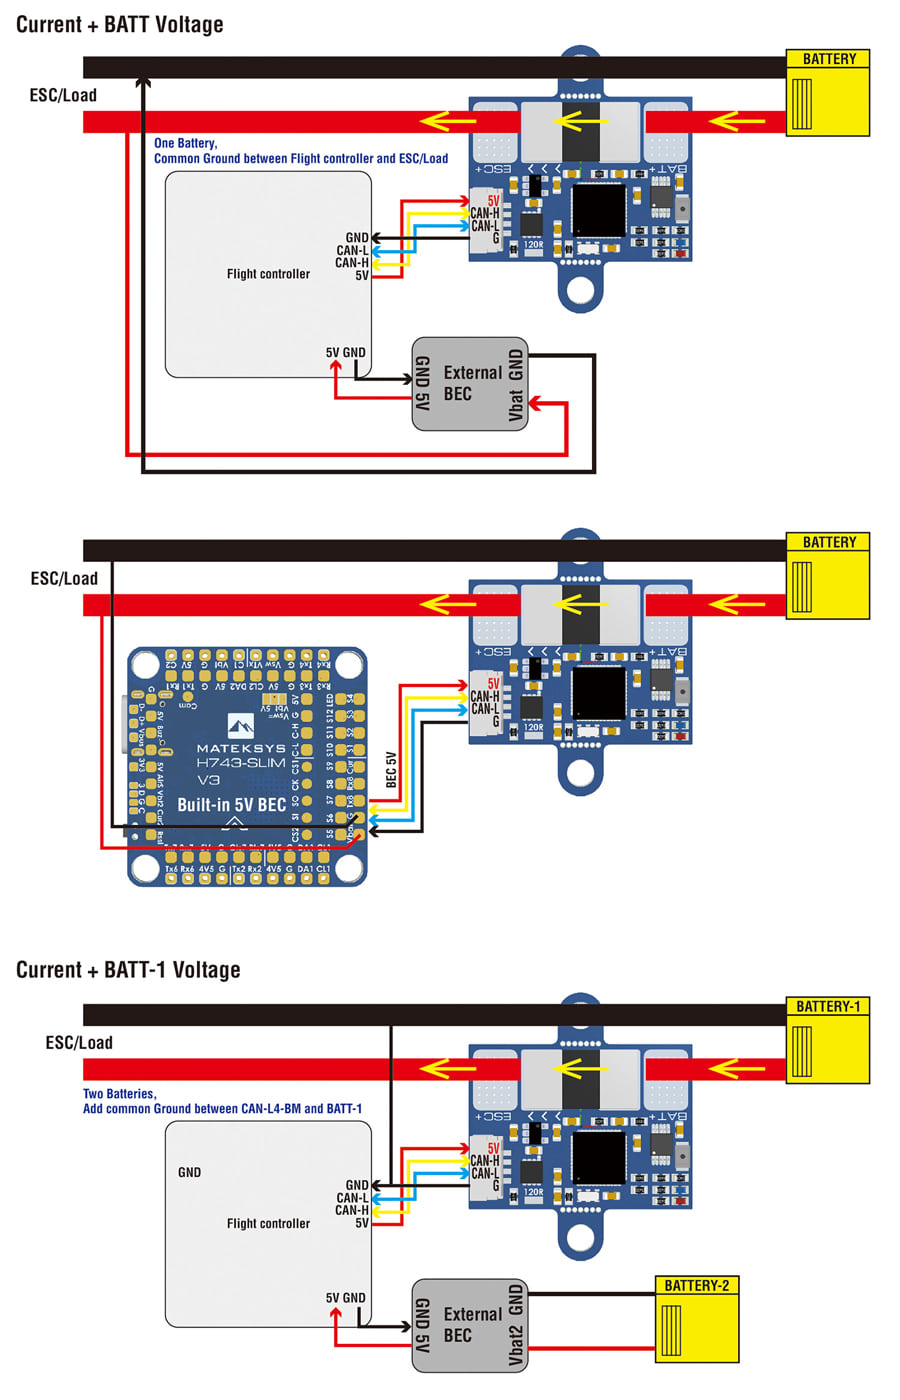
With this device, No calibration required, flight controller that support DroneCAN protocol can easily get accurate current & bus voltage readouts via CAN bus.
Specifications
MCU: STM32L431xC, 256KB Flash
INA239 85-V, 16-Bit, High-Precision Power monitor IC With SPI Interface
Battery Voltage sense input: 0~85V
Current Sense Range: 0~204.8A
Load current on current sensing resistor: 150A(Continuous), 204.8A(Burst)
Voltage accuracy: ± 0.1%
Current accuracy: ± 2%
Interface
CAN, DroneCAN Protocol
UART2, spare, DFU
ST debug, SWCLK & SWDIO
LED
Blue, Fast blinking, Booting
Blue, Slow blinking, working
Red, 3.3V indicator
Power supply for CAN-L4-BM board : 4.5~5.5V @5V pad/pin
Power consumption: 10mA
Operating Temperatures: -40~85 °C
Physical
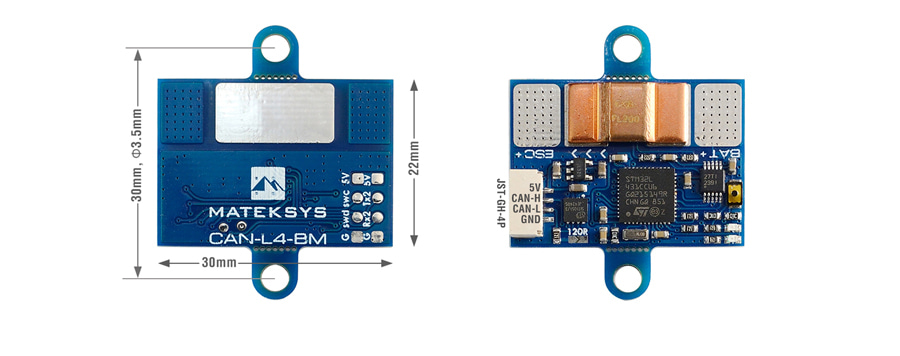
Board Size: 30mm*22mm*3mm. 4g
3D file : CAN-L4-BM_STEP.zip
Firmware
ArduPilot AP_Periph MatekL431-BattMon
Update via DroneCAN GUI Tool
Parameters
CAN_P1_DRIVER = 1 if attached to CAN bus1 port or CAN_P2_DRIVER = 1 if attached to CAN bus2 port
BATTx_MONITOR = 8 (DroneCAN-BatteryInfo)
BATTx_OPTIONS = 1
Packing
1x CAN-L4-BM board
1x JST-GH-4P to JST-GH-4P 20cm silicon wire
Tips
The big pad on the bottom side is a dead pad. No any circuit network on it.
Solder the positive wires as close as possible to both sides of the current sensing resistor.
2 ears for mounting can be cut off if you don’t need it.
If the CAN wires are too long, bridge the “120R” jumper.



 10월 12일 출고