Holybro 예약 상품 배송 일정
- 홀리브로(Holybro) 제품은 예약시 발송까지 2~3주 소요 예상됩니다.
(최근 6개월 주문 기준 · 3주 이내 발송 95%)
* 예약 상품은 주문시 해외로 발주가 되는 상품으로 국내에 재고가 없습니다.* 주문건 중 일부 예약 상품이 포함되어 있을 경우, 모든 상품이 준비된 후 일괄 배송됩니다.
예약 상품만 따로 배송을 원하시는 경우 주문을 따로 해주시기 바랍니다.
* 네이버페이 주문시 예약발송 처리되며 상품 수령 후 구매확정 하시면 됩니다.
* 상품별로 입고 시기가 다르므로 배송 일정에 대해서는 고객센터로 문의주시기 바랍니다.
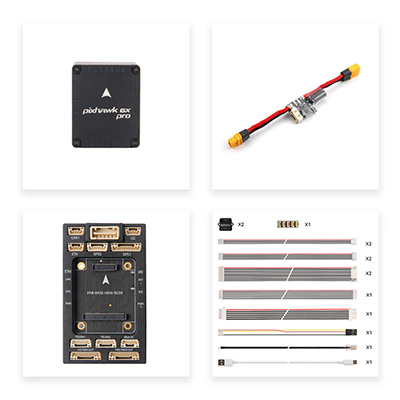
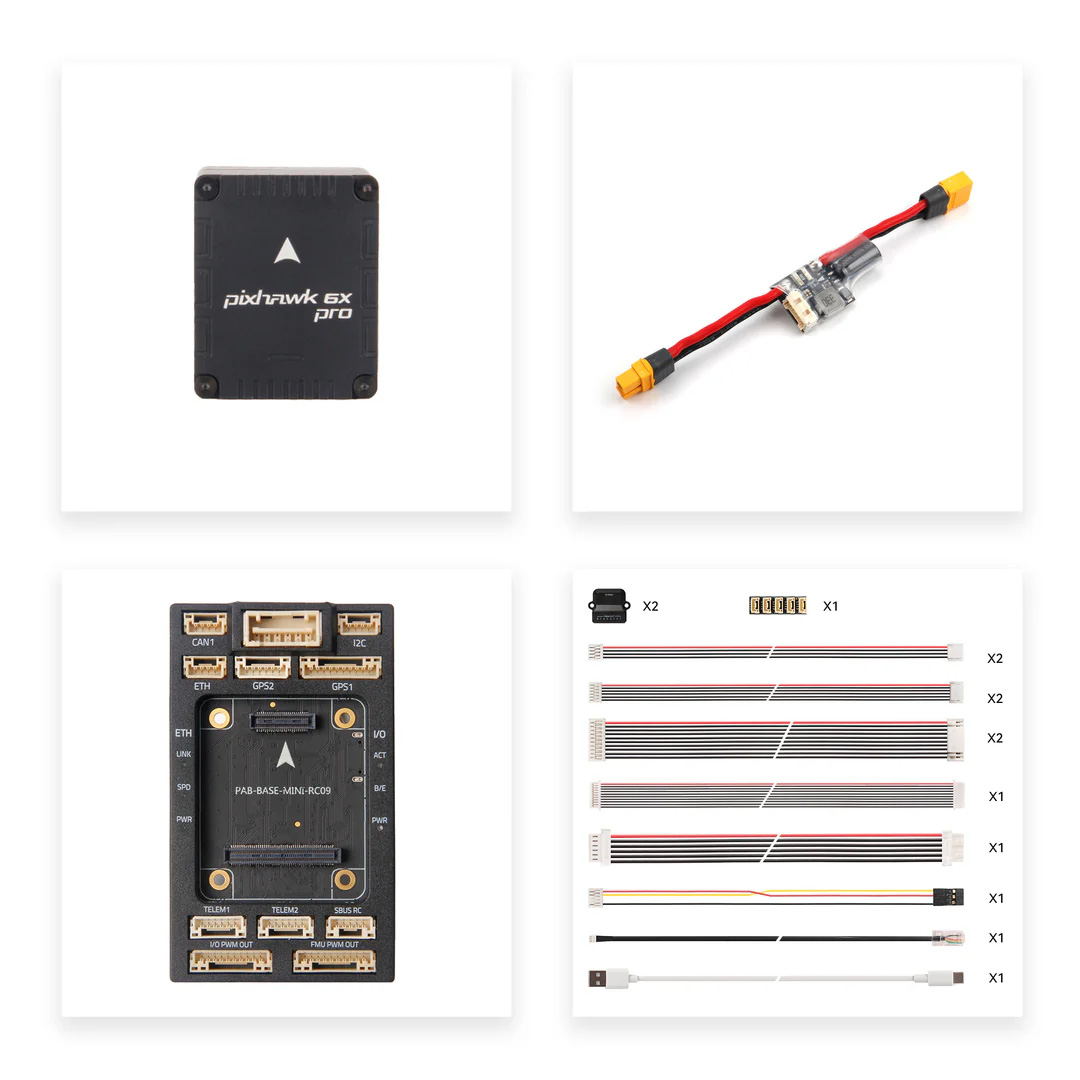
Holybro Pixhawk 6X Pro 미니
- High-performance ADIS16470 Industrial IMU with high accelerometer dynamic range (±40 g), perfect for accurate motion sensing in demanding UAV applications
- All New advanced durable vibration isolation material with resonance frequency in the higher spectrum, ideal for industrial and commercial drone applications
- Triple redundant IMU & double redundant barometer on separate buses
- High performance STM32H753 Processor
- Modular flight controller: separated IMU, FMU, and Base system
- Safety-driven design incorporates sensors from different manufacturers and model lineups
- Independent LDO powers every sensor set with independent power control.
- Ethernet interface for high-speed mission computer integration
- Temperature-controlled IMU board, allowing optimum working temperature of IMUs
All new Vibration Isolation Design
This new vibration isolation design uses a custom-formulated durabile silicone-based isolation material in place of the traditional foam design. Backed by extensive R&D and testing, it offers optimal IMU damping characteristics with resonance frequency in the higher spectrum, perfect for industrial and commercial drone
Technical Specification
Processors & Sensors
- FMU Processor: STM32H753
- 32 Bit Arm? Cortex?-M7, 480MHz, 2MB flash memory, 1MB RAM
- IO Processor: STM32F103
- 32 Bit Arm? Cortex?-M3, 72MHz, 64KB SRAM
- On-board sensors
- Accel/Gyro: ADIS16470 (±40g, Vibration Isolated, Industrial IMU)
- Accel/Gyro: IIM-42652 (±16g, Vibration Isolated, Industrial IMU)
- Accel/Gyro: ICM-45686 with BalancedGyro™ Technology (±32g, Hard Mounted)
- Barometer: ICP20100
- Barometer: BMP388
- Mag: BMM150
- NXP EdgeLock SE050 Plug & Trust hardware secure element
- Voltage Ratings:
- Max input voltage: 6V
- USB Power Input: 4.75~5.25V
- Servo Rail Input: 0~36V
- Current Ratings:
- Telem1 output current limiter: 1.5A
- All other port combined output current limiter: 1.5A
- Dimensions
- Flight Controller Module: 38.8 x 31.8 x 30.1mm
- Standard Baseboard: 52.4 x 103.4 x 16.7mm
- Mini Baseboard: 43.4 x 72.8 x 14.2 mm
- Weight
- Flight Controller Module: 50g
- Standard Baseboard: 72.5g (Aluminum)
- Mini Baseboard: 26.5g
- 16- PWM servo outputs
- R/C input for Spektrum / DSM
- Dedicated R/C input for PPM and S.Bus input
- Dedicated analog / PWM RSSI input and S.Bus output
- 4 general purpose serial ports
- 3 with full flow control
- 1 with separate 1.5A current limit (Telem1)
- 1 with I2C and additional GPIO line for external NFC reader
- 2 GPS ports
- 1 full GPS plus Safety Switch Port
- 1 basic GPS port
- 1 I2C port
- 1 Ethernet port
- Transformerless Applications
- 100Mbps
- 1 SPI bus
- 2 chip select lines
- 2 data-ready lines
- 1 SPI SYNC line
- 1 SPI reset line
- 2 CAN Buses for CAN peripheral
- CAN Bus has individual silent controls or ESC RX-MUX control
- 2 Power input ports with SMBus
- 1 AD & IO port
- 2 additional analog input
- 1 PWM/Capture input
- 2 Dedicated debug and GPIO lines
- Operating temperature: -40 ~ 85°c
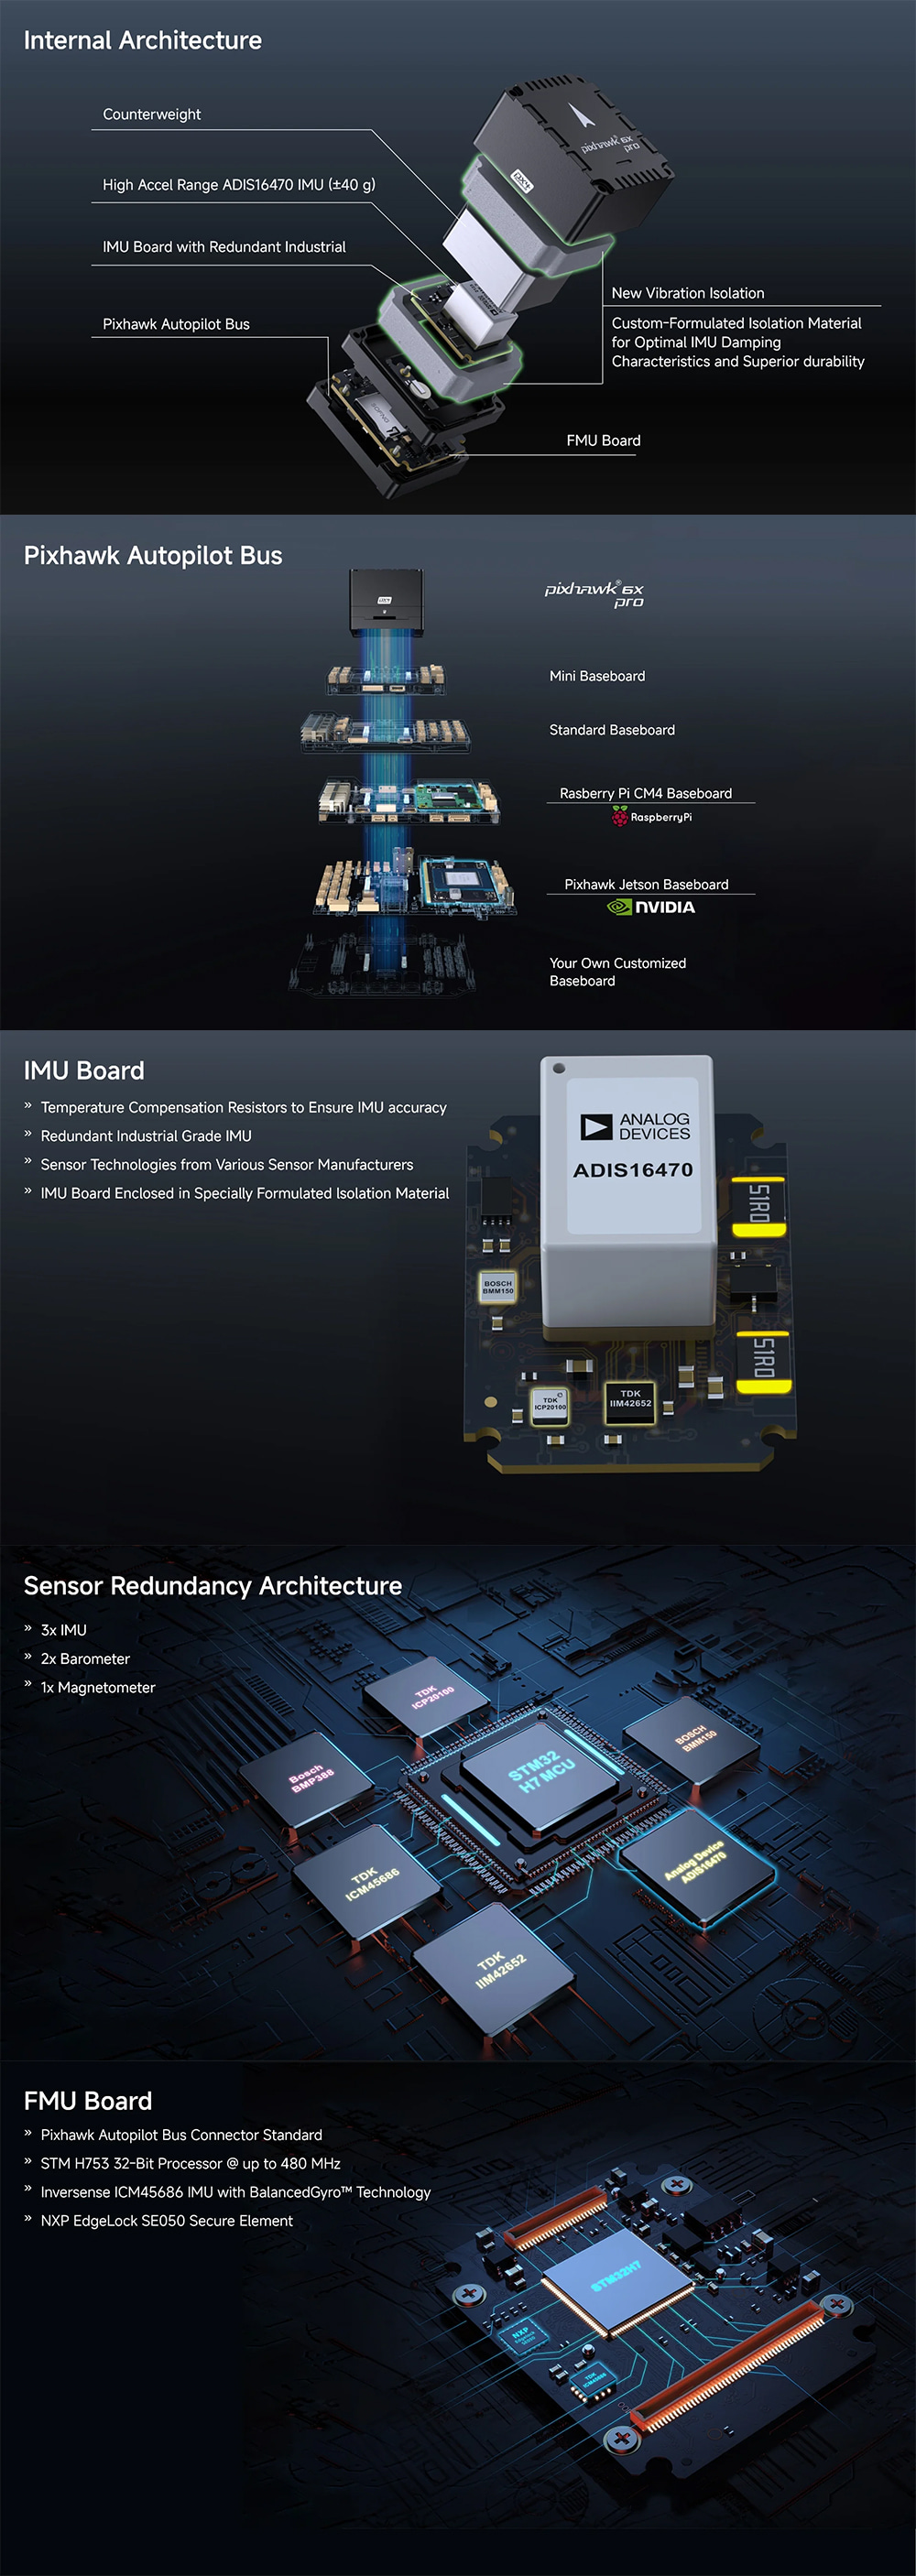
내부 구조
- 카운터웨이트
- 높은 가속도 범위의 ADIS16470 IMU (±40 g)
- 산업용 이중화 IMU 보드
- Pixhawk Autopilot Bus
- FMU 보드
- 새로운 진동 절연: IMU 감쇠 특성을 최적화하고 내구성이 뛰어난 전용 배합 절연 소재
Pixhawk Autopilot Bus
Pixhawk 6X Pro 는 다음 베이스보드와 함께 쓸 수 있습니다.
- Mini Baseboard
- Standard Baseboard
- Raspberry Pi CM4 Baseboard
- Pixhawk Jetson Baseboard (NVIDIA)
- 직접 설계한 맞춤 베이스보드
IMU 보드
- IMU 정확도를 위한 온도 보상 저항
- 산업용 등급 이중화 IMU
- 여러 센서 제조사의 센서 기술 사용
- 전용 배합 절연 소재로 감싼 IMU 보드
센서 이중화 구조
- IMU 3개
- 기압계 2개
- 지자기 센서 1개
(사진의 칩: STM32 H7 MCU, Analog Device ADIS16470, TDK ICM45686, TDK IIM42652, TDK ICP20100, Bosch BMP388, Bosch BMM150)
FMU 보드
- Pixhawk Autopilot Bus 커넥터 표준
- STM H753 32비트 프로세서 @ 최대 480 MHz
- BalancedGyro™ 기술의 Inversense ICM45686 IMU
- NXP EdgeLock SE050 보안 소자
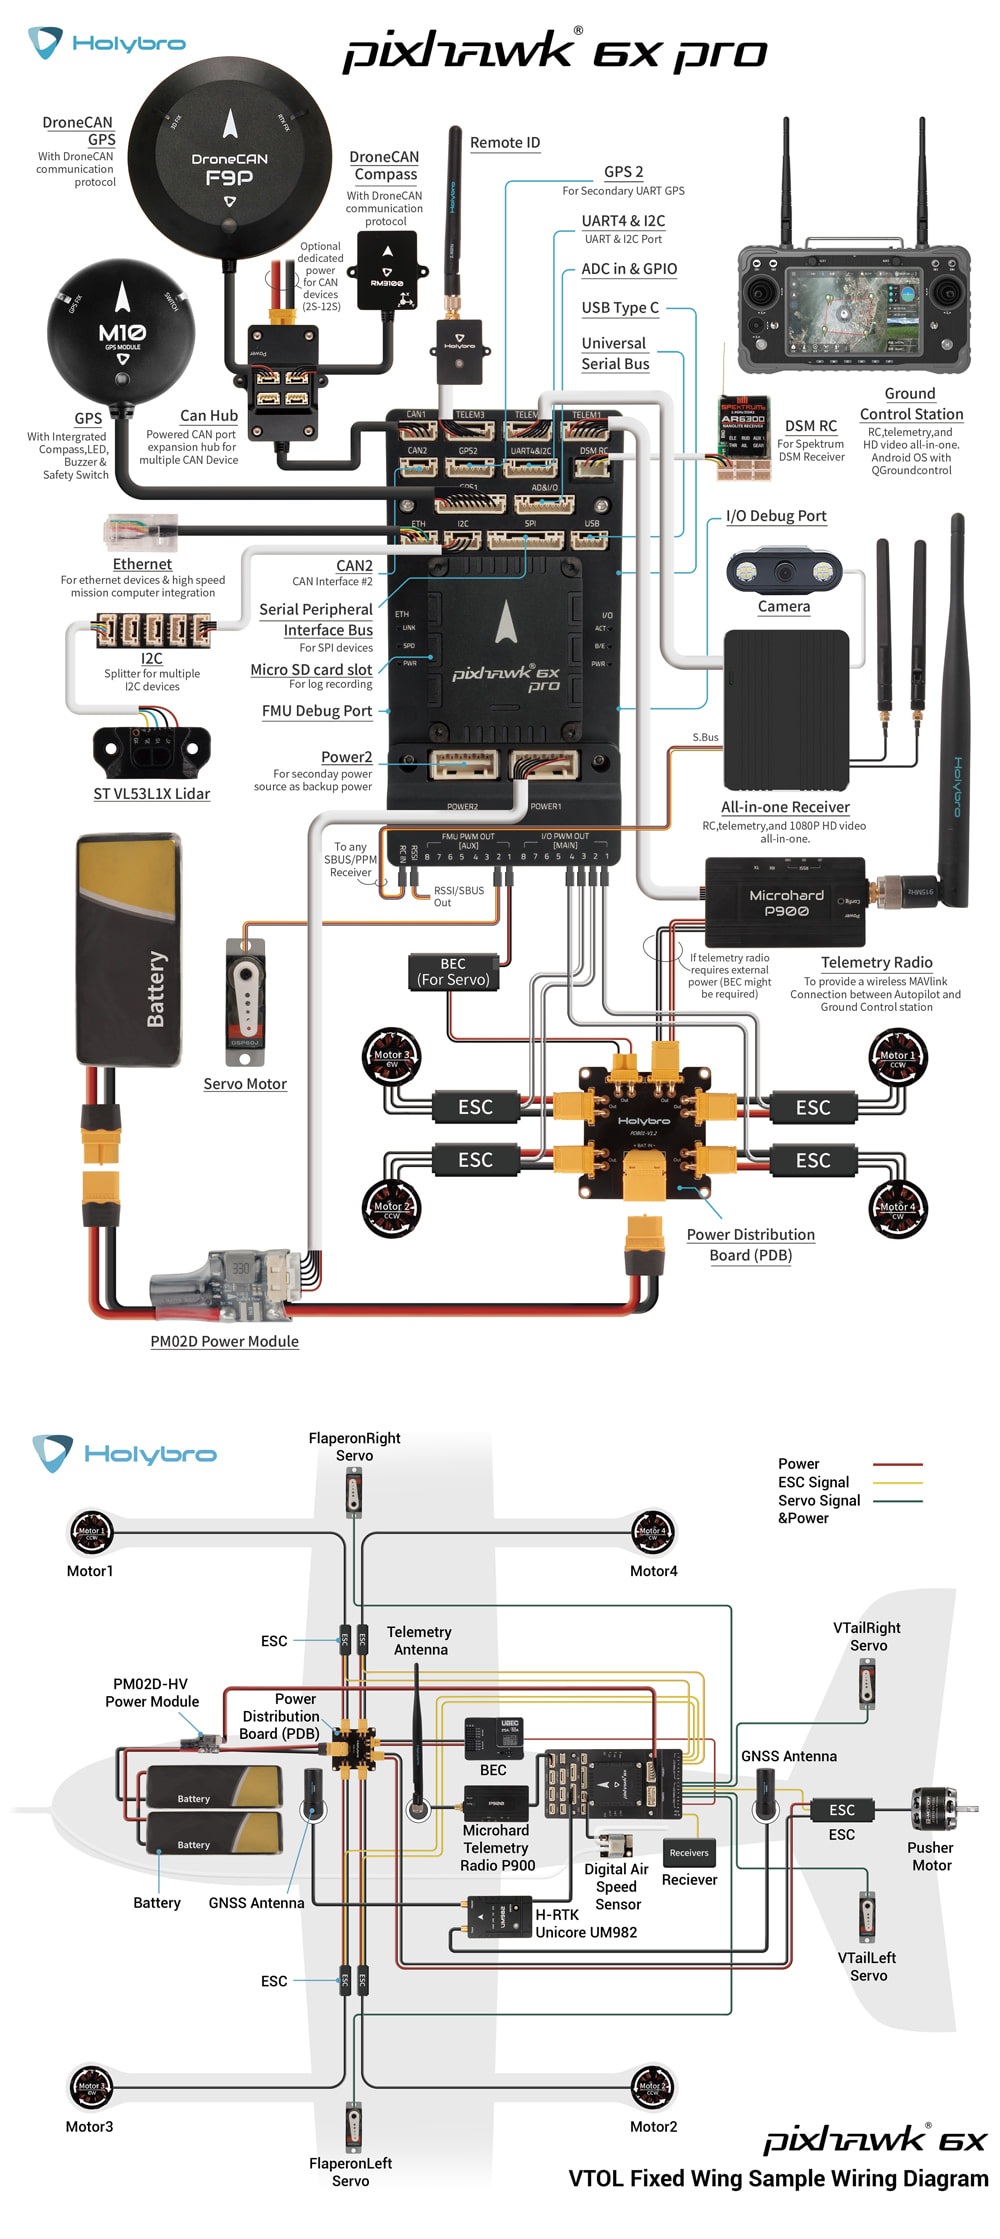
Pixhawk 6X Pro 연결 예시 (멀티콥터)
포트 설명
- GPS 2: 보조 UART GPS용
- UART4 & I2C: UART·I2C 포트
- ADC in & GPIO
- USB Type C
- Universal Serial Bus
- DSM RC: Spektrum DSM 수신기용
- CAN2: 두 번째 CAN 인터페이스
- Ethernet: 이더넷 장치·고속 미션 컴퓨터 연결용
- I2C: 여러 I2C 장치용 분배기
- SPI(Serial Peripheral Interface Bus): SPI 장치용
- Micro SD 카드 슬롯: 로그 기록용
- FMU 디버그 포트, I/O 디버그 포트
- Power2: 백업용 보조 전원
- RC IN: SBUS/PPM 수신기 연결, RSSI/SBUS 출력
- FMU PWM OUT [AUX] 1-8, I/O PWM OUT [MAIN] 1-8
연결 장치
- DroneCAN GPS(F9P), DroneCAN 나침반(RM3100): DroneCAN 통신 프로토콜
- CAN 허브: 여러 CAN 장치를 위한 전원 공급형 CAN 포트 확장 허브(CAN 장치용 별도 전원 2S-12S 선택)
- GPS(M10): 나침반·LED·부저·안전 스위치 내장
- Remote ID, ST VL53L1X 라이다, 카메라
- 지상 통제소: RC·텔레메트리·HD 영상 일체형, Android OS, QGroundcontrol
- 일체형 수신기: RC·텔레메트리·1080P HD 영상 일체형
- 텔레메트리 라디오(Microhard P900): 오토파일럿과 지상 통제소 사이 무선 MAVLink 연결. 외부 전원이 필요하면 BEC 가 필요할 수 있음
- 서보 모터와 서보용 BEC, ESC 4개, 전원 분배 보드(PDB), 배터리, PM02D 전원 모듈
VTOL 고정익 배선 예시 그림도 함께 있습니다(PM02D-HV 전원 모듈, Microhard P900, H-RTK Unicore UM982, 디지털 대기속도 센서, GNSS 안테나, 푸셔 모터, 플래퍼론·V테일 서보).
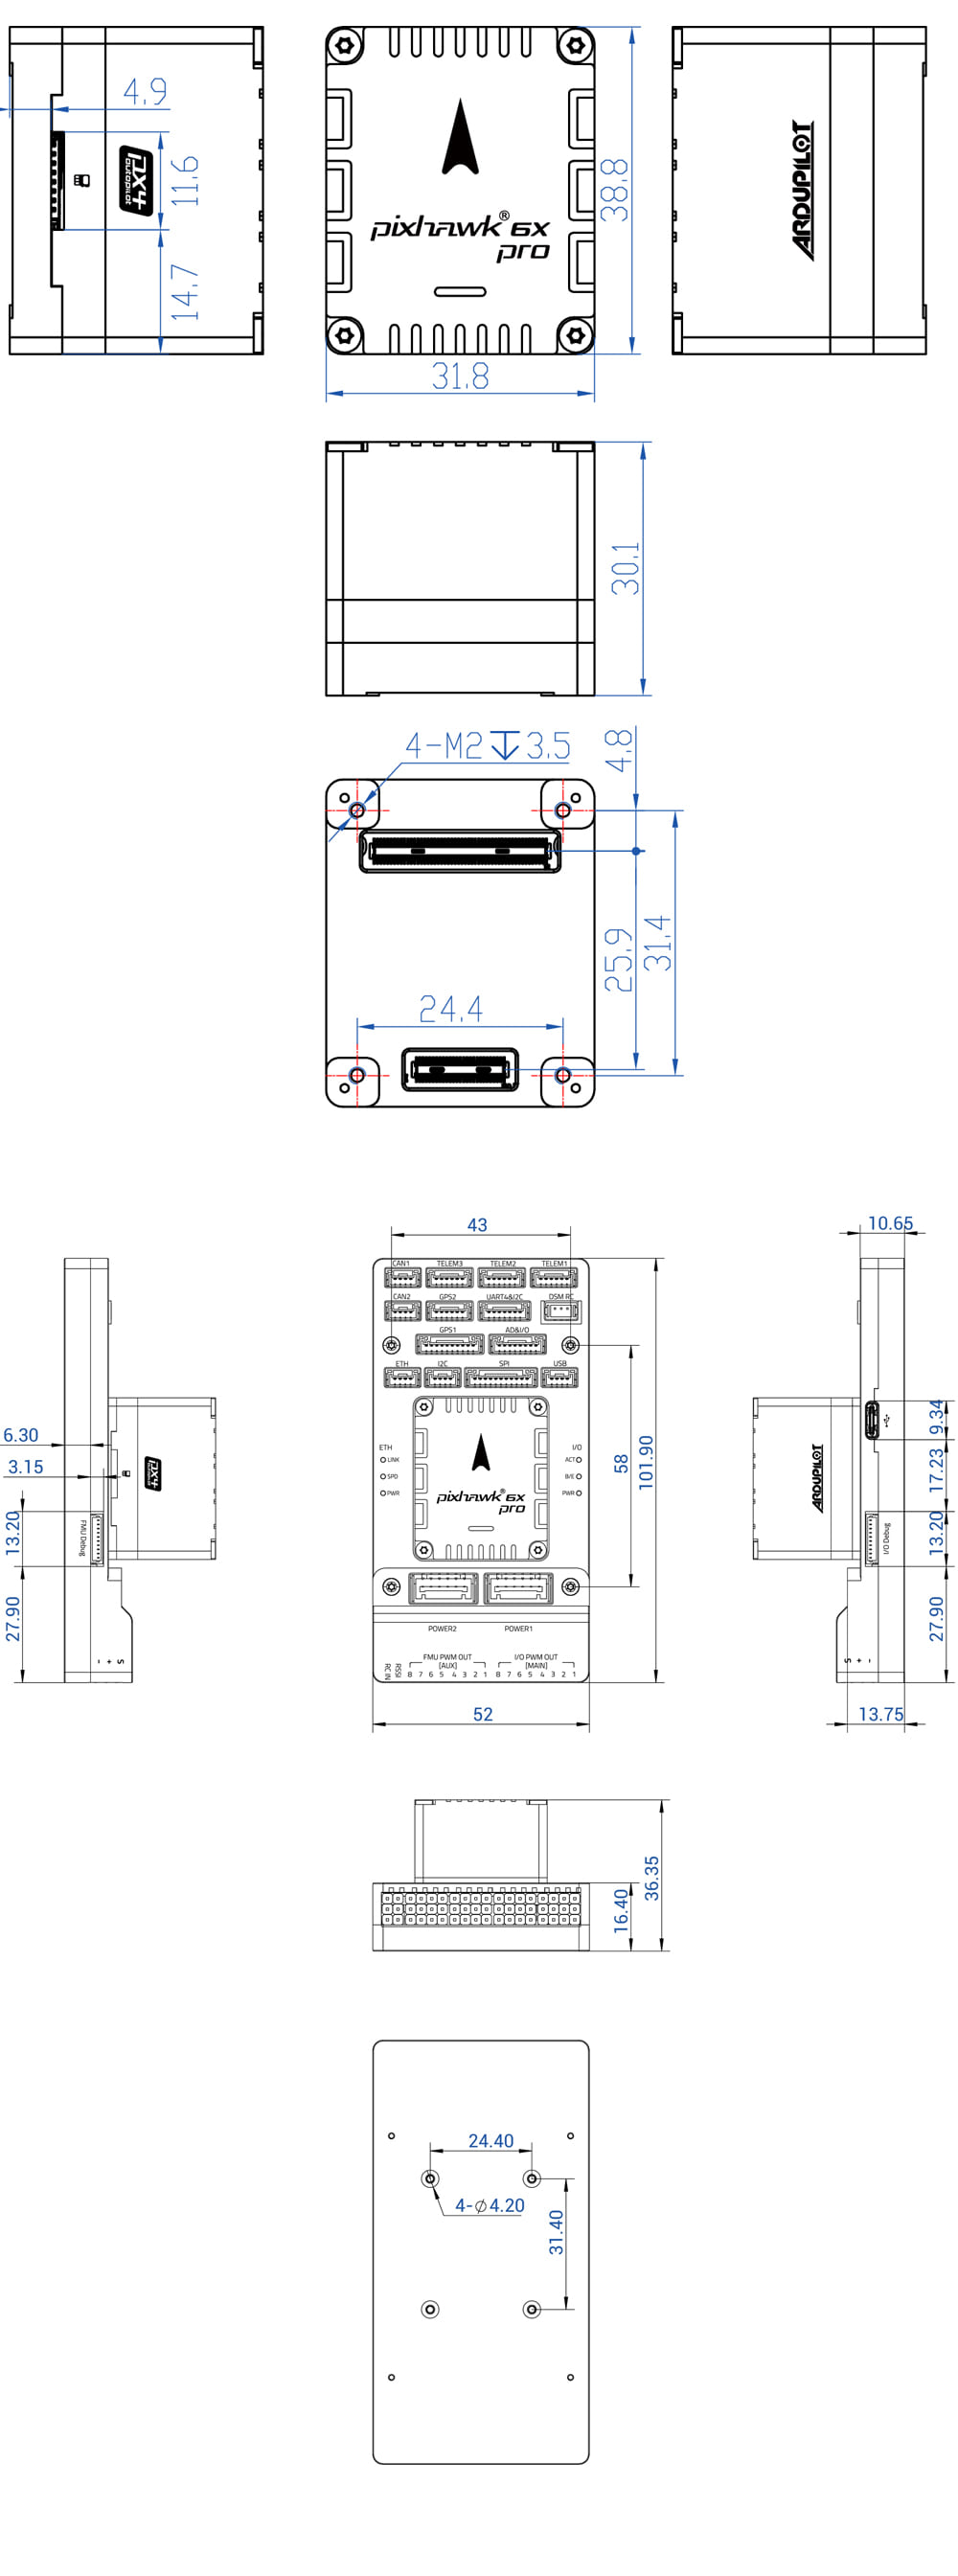
치수 (mm)
- 비행 컨트롤러 모듈: 31.8 x 38.8, 높이 30.1
- 모듈 장착 구멍: 4-M2 깊이 3.5, 간격 24.4 x 25.9
- 미니 베이스보드 포함: 52 x 101.90, 높이 36.35(베이스보드 16.40)
- 베이스보드 장착 구멍: 4-Ø4.20, 간격 24.40 x 31.40
- 포트: CAN1, TELEM3, TELEM2, TELEM1, CAN2, GPS2, UART4&I2C, DSM RC, GPS1, AD&IO, ETH, I2C, SPI, USB, POWER1, POWER2, FMU PWM OUT [AUX] 1-8, I/O PWM OUT [MAIN] 1-8, RC IN, RSSI, FMU Debug, I/O Debug