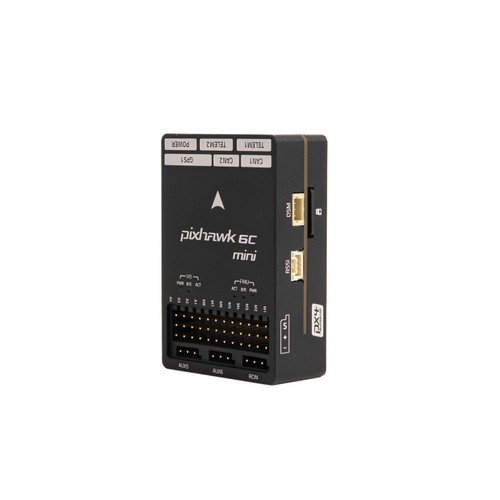
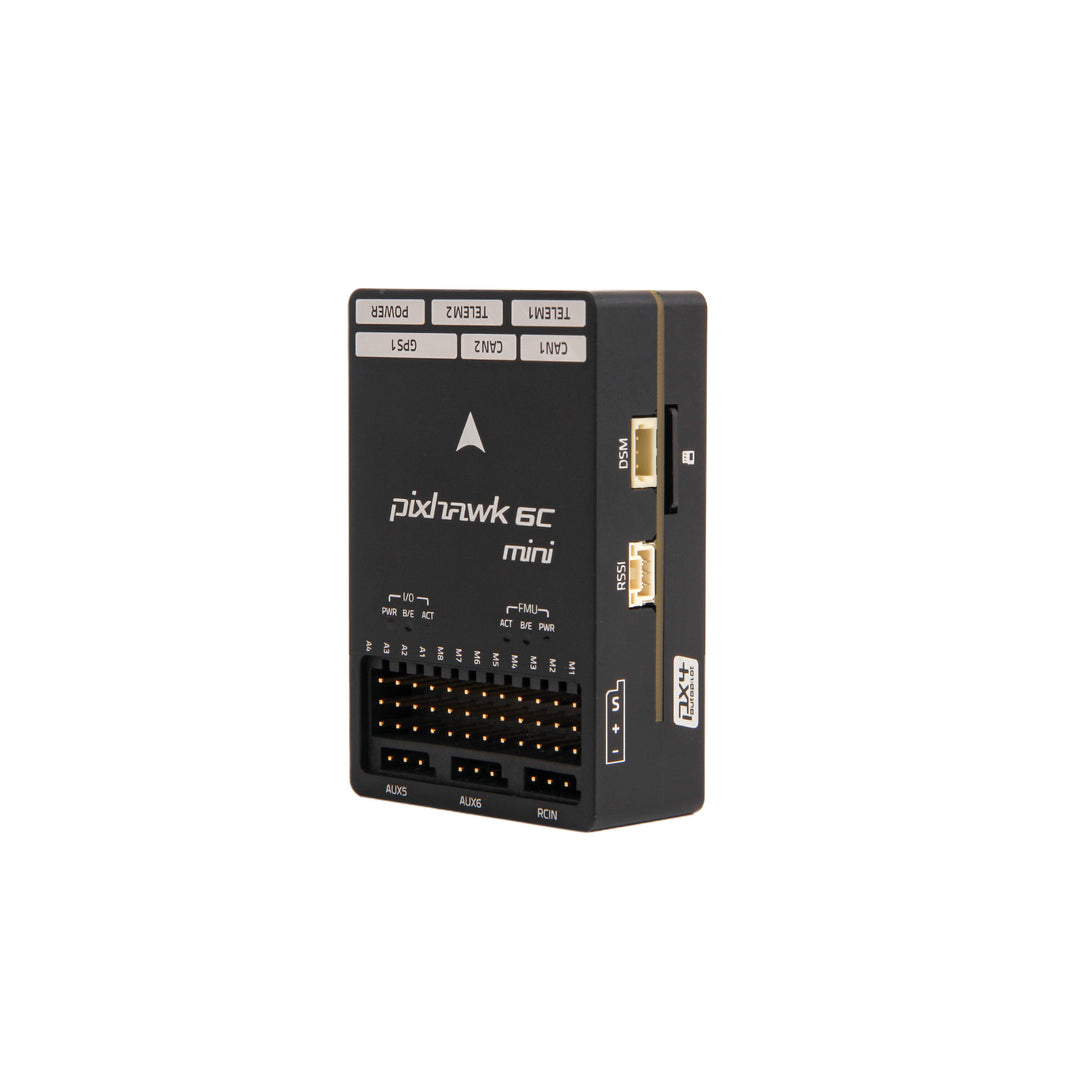
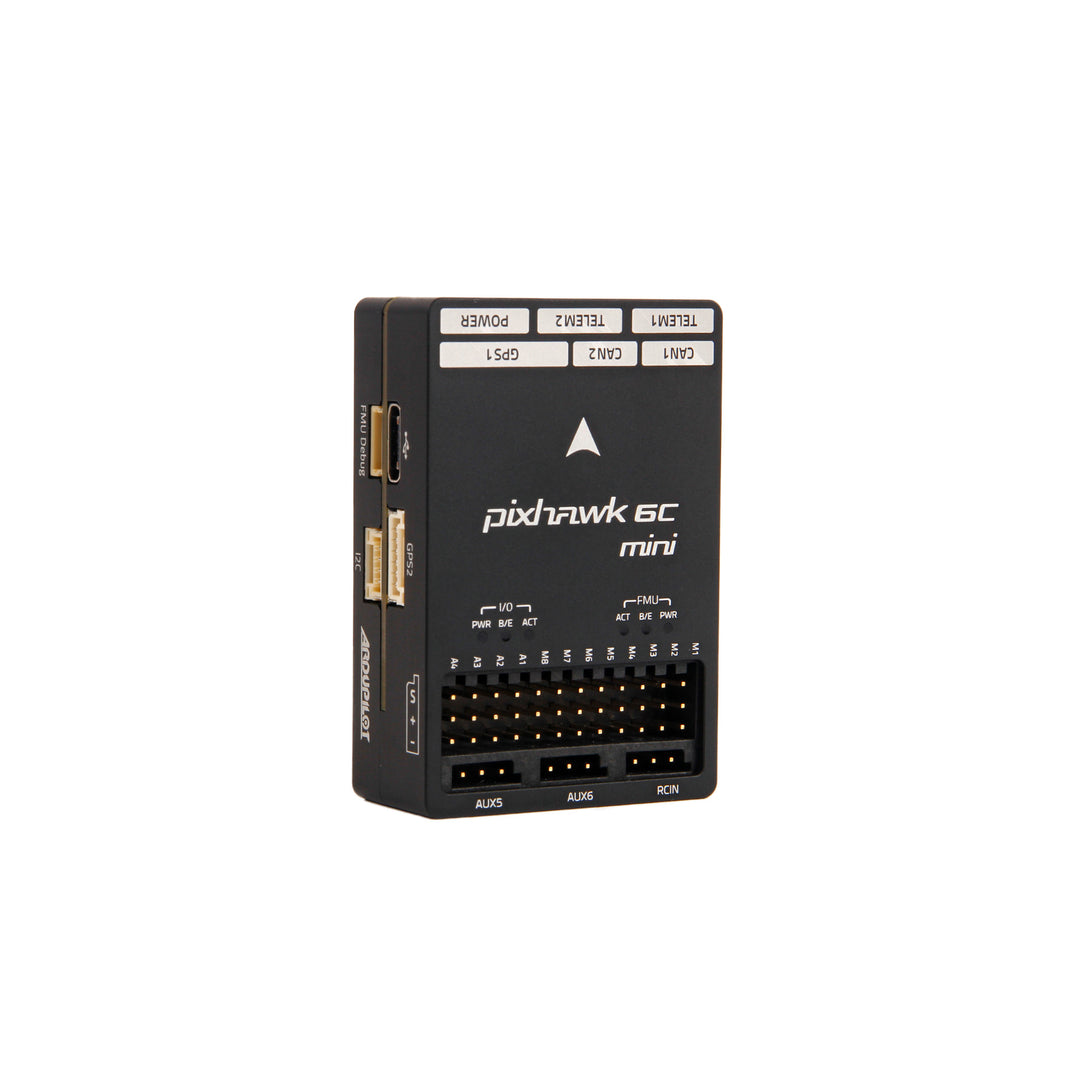
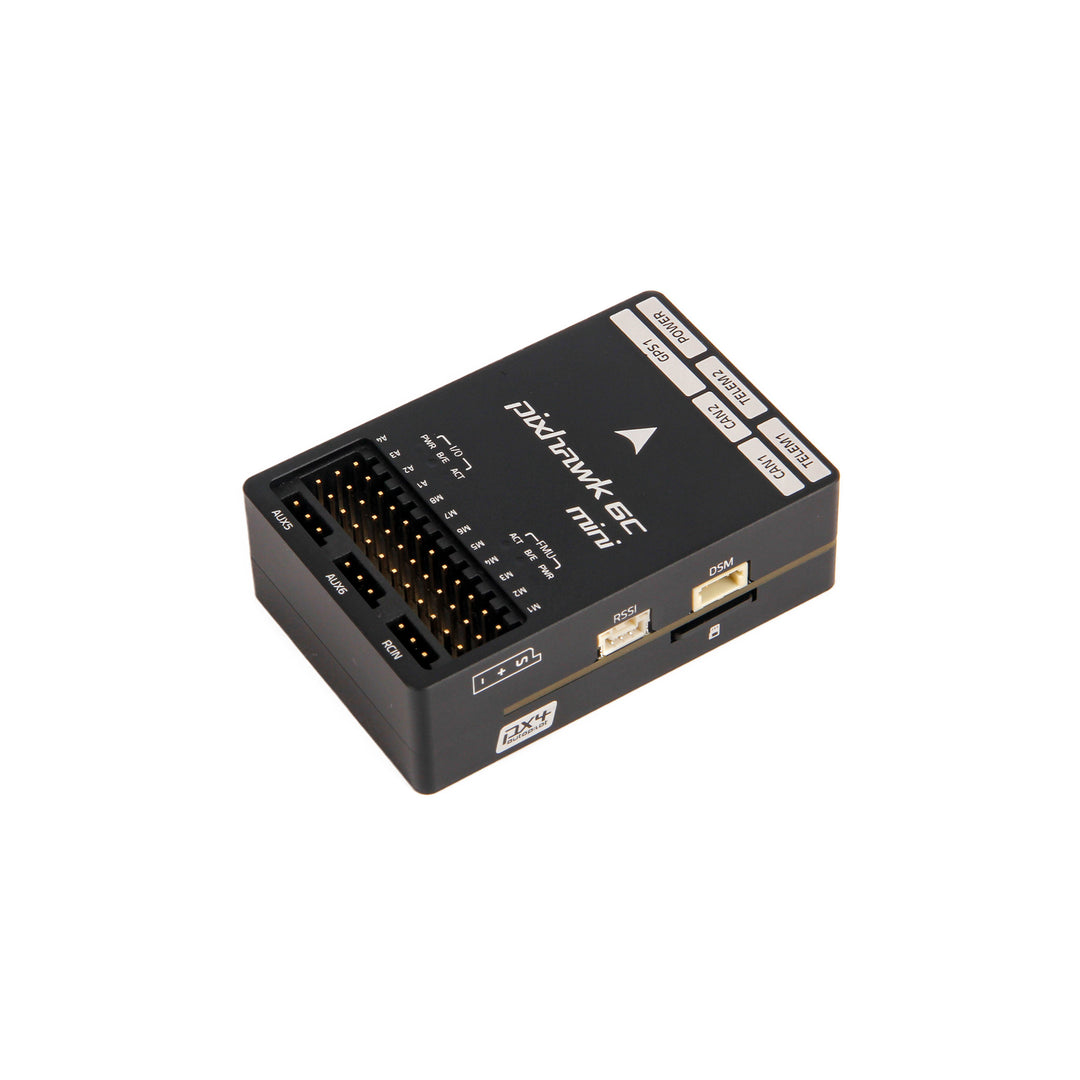
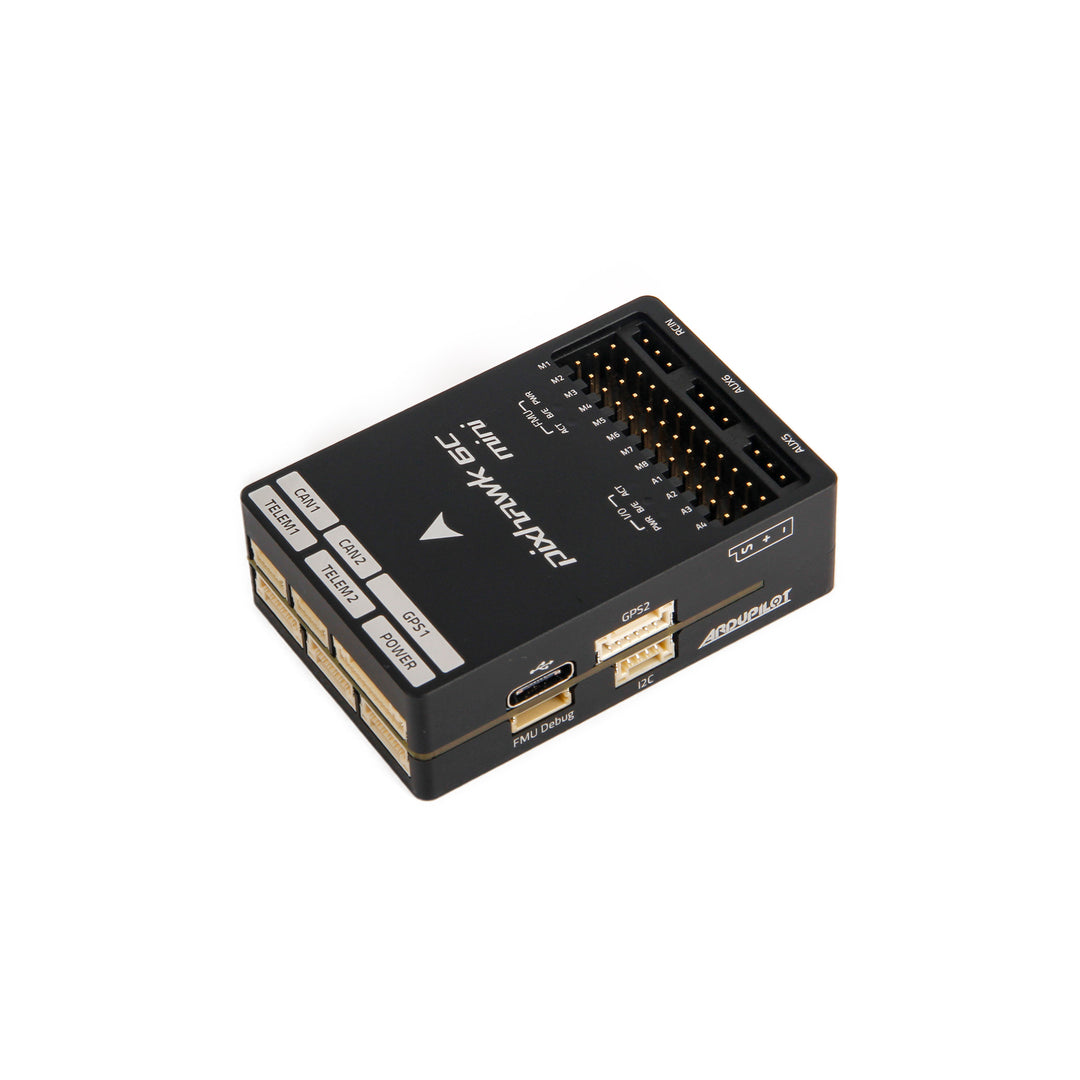
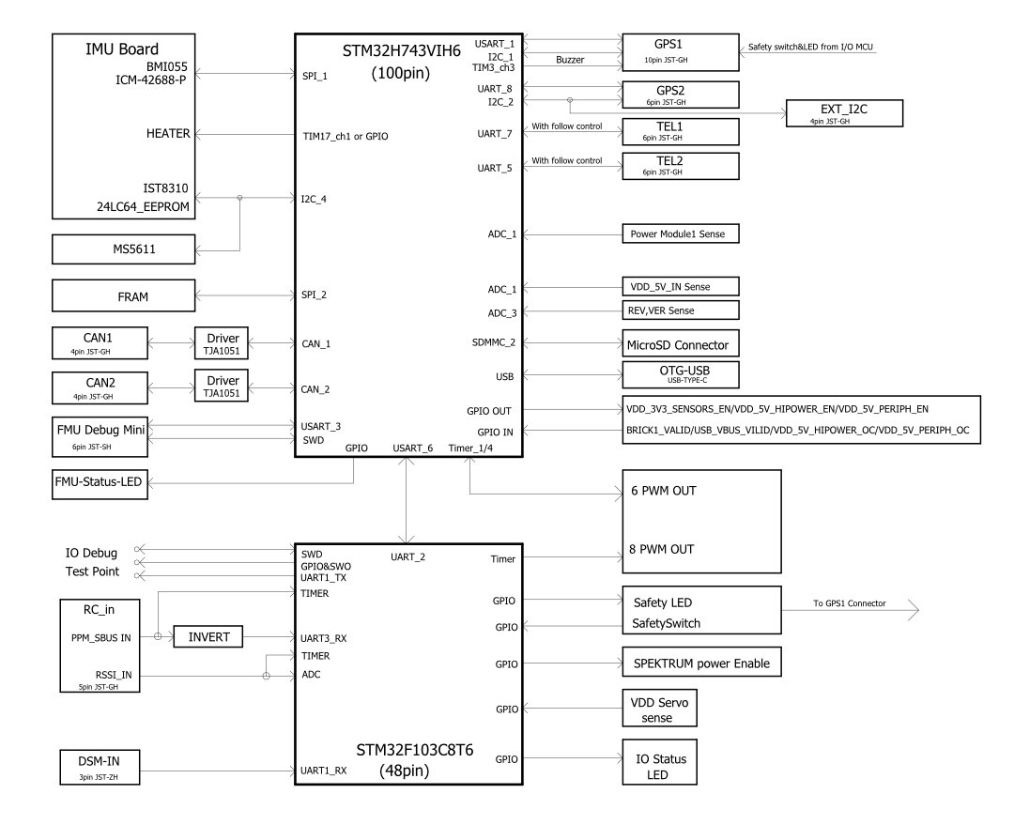
32 Bit Arm? Cortex?-M7, 480MHz, 2MB memory, 1MB SRAM
IO Processor
STM32F103
32 Bit Arm? Cortex?-M3, 72MHz, 64KB SRAM On-board sensors
Accel/Gyro
ICM-42688-P
Accel/Gyro
BMI055
Mag
IST8310
Barometer
MS5611
Electrical data
Voltage Ratings
Max input voltage: 6V
USB Power Input: 4.75~5.25V
Servo Rail Input: 0~36V
Current Ratings:
Telem1 Max output current limiter: 1.5A
All other port combined output current limiter: 1.5A
Mechanical data
Dimensions
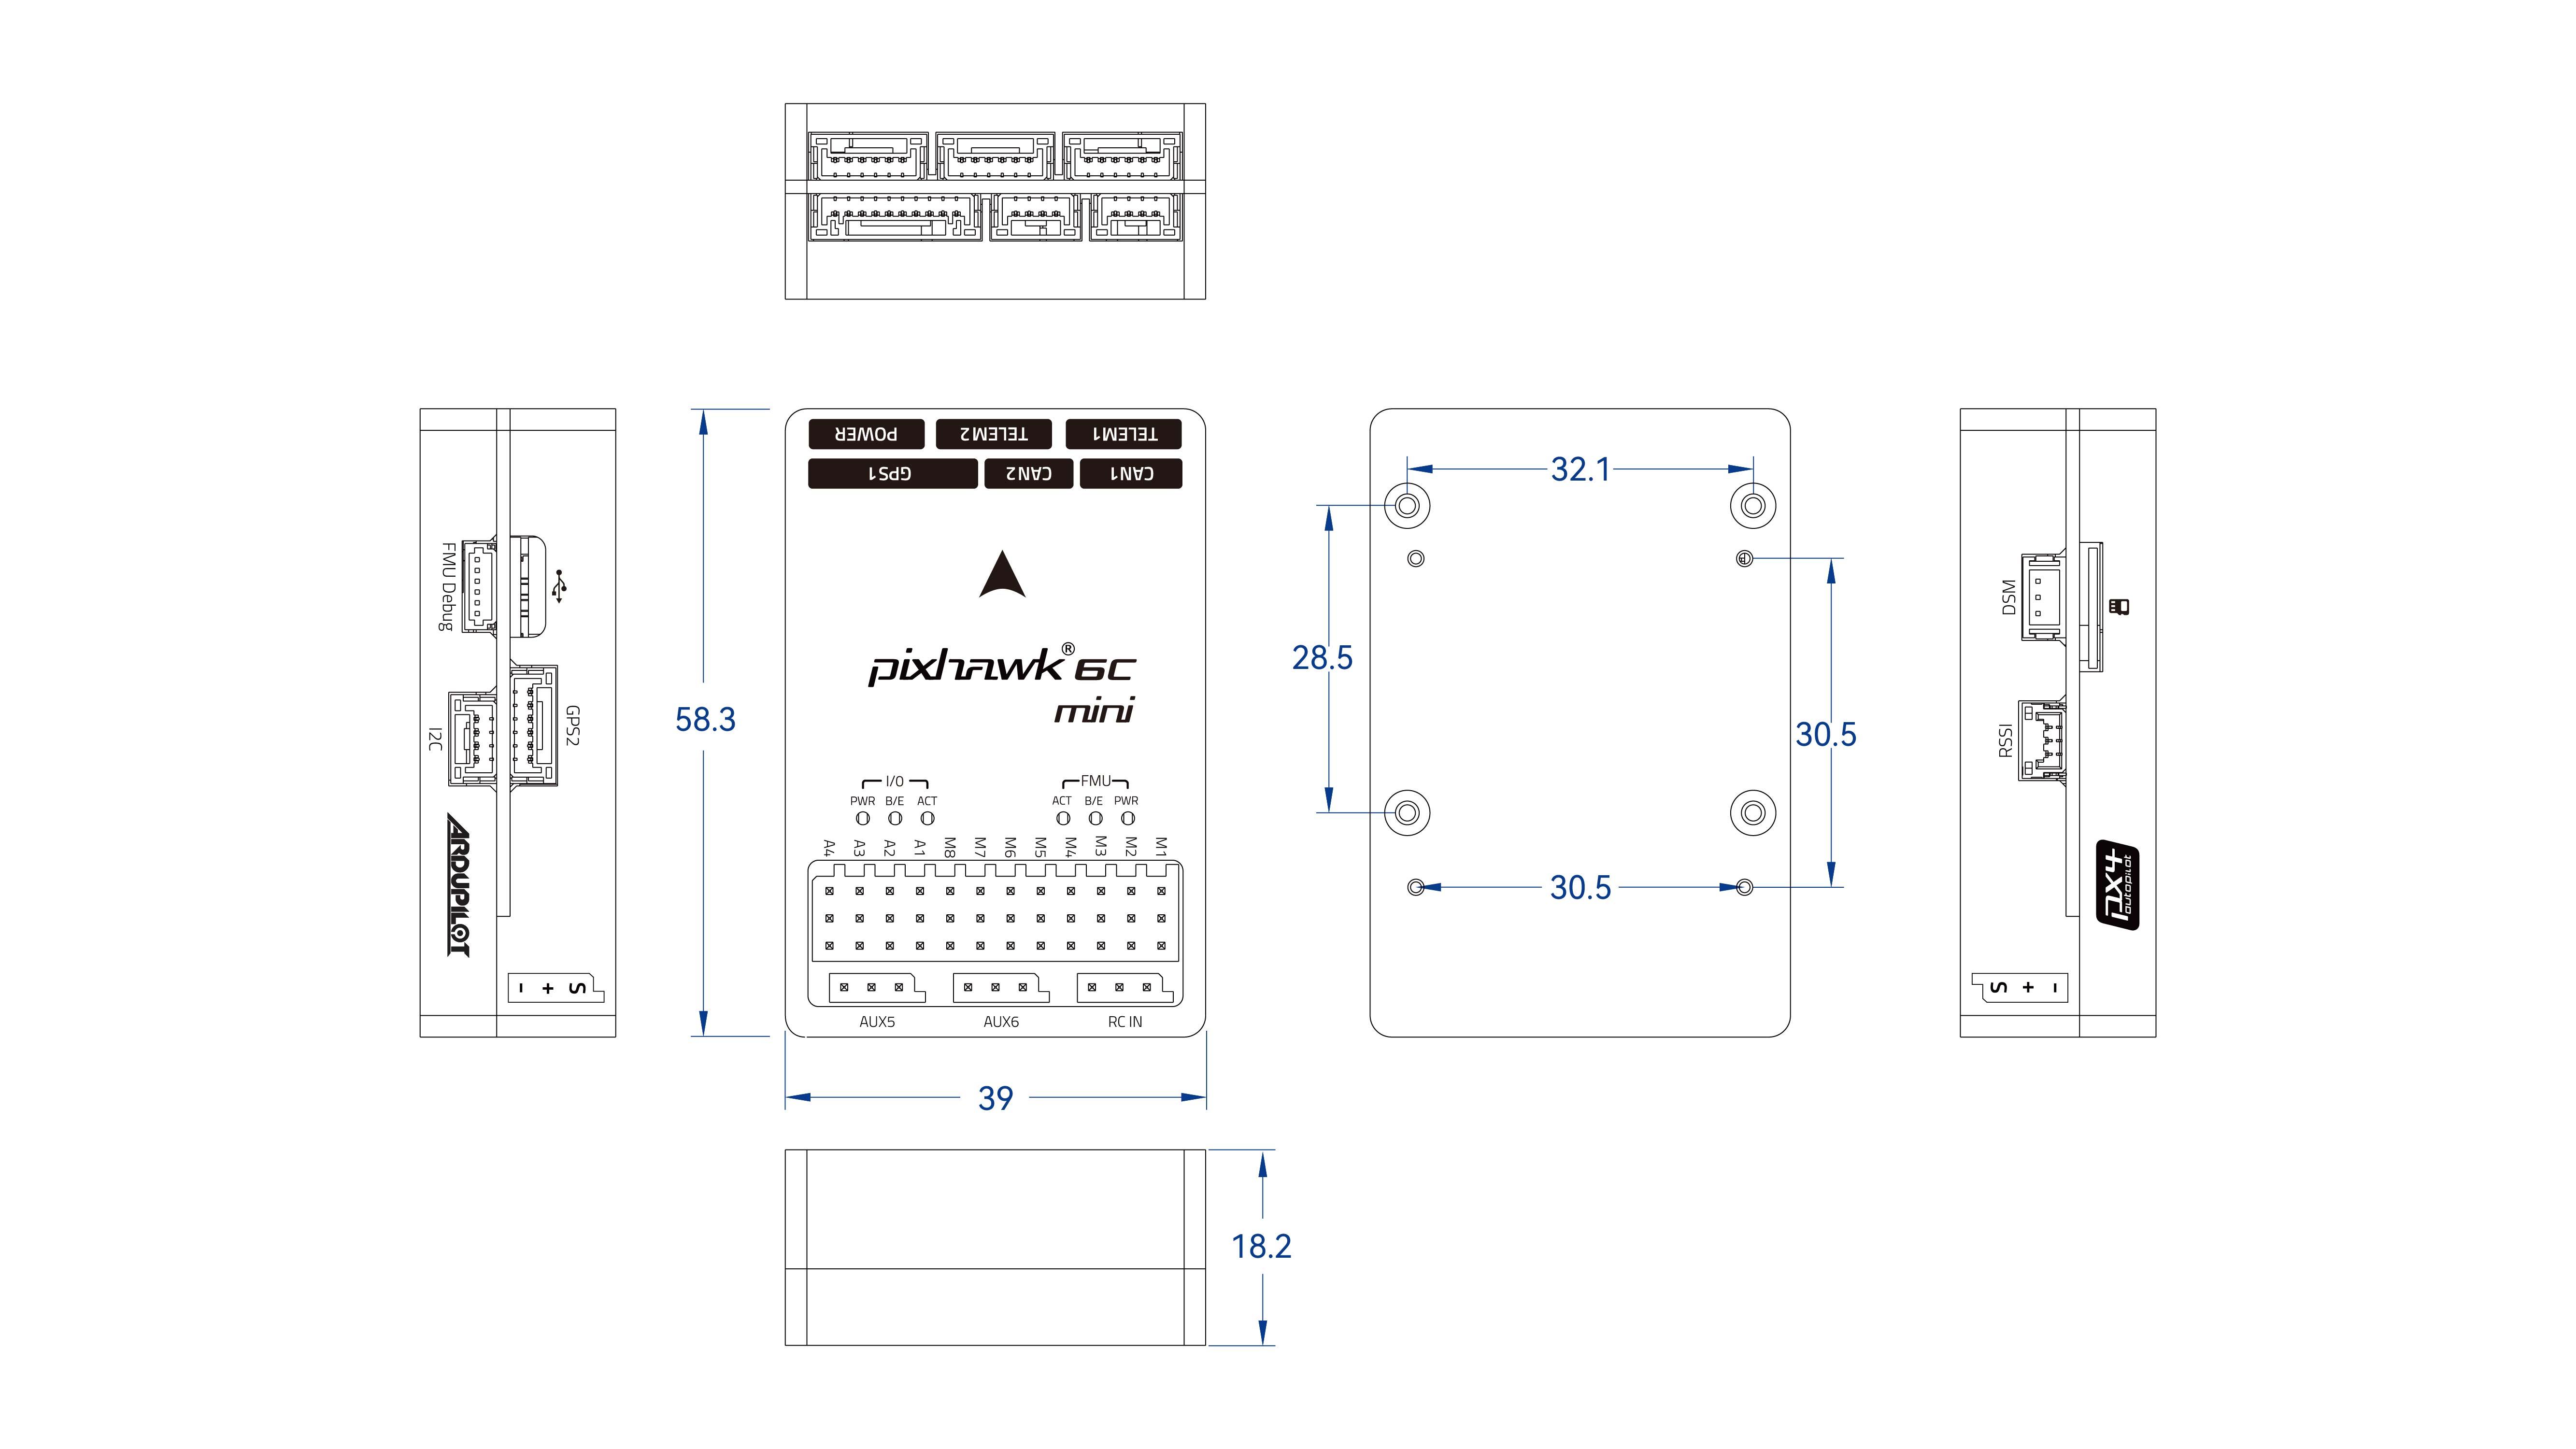
53.3 * 39 * 16.2 mm
Weight
39.2g
Interfaces
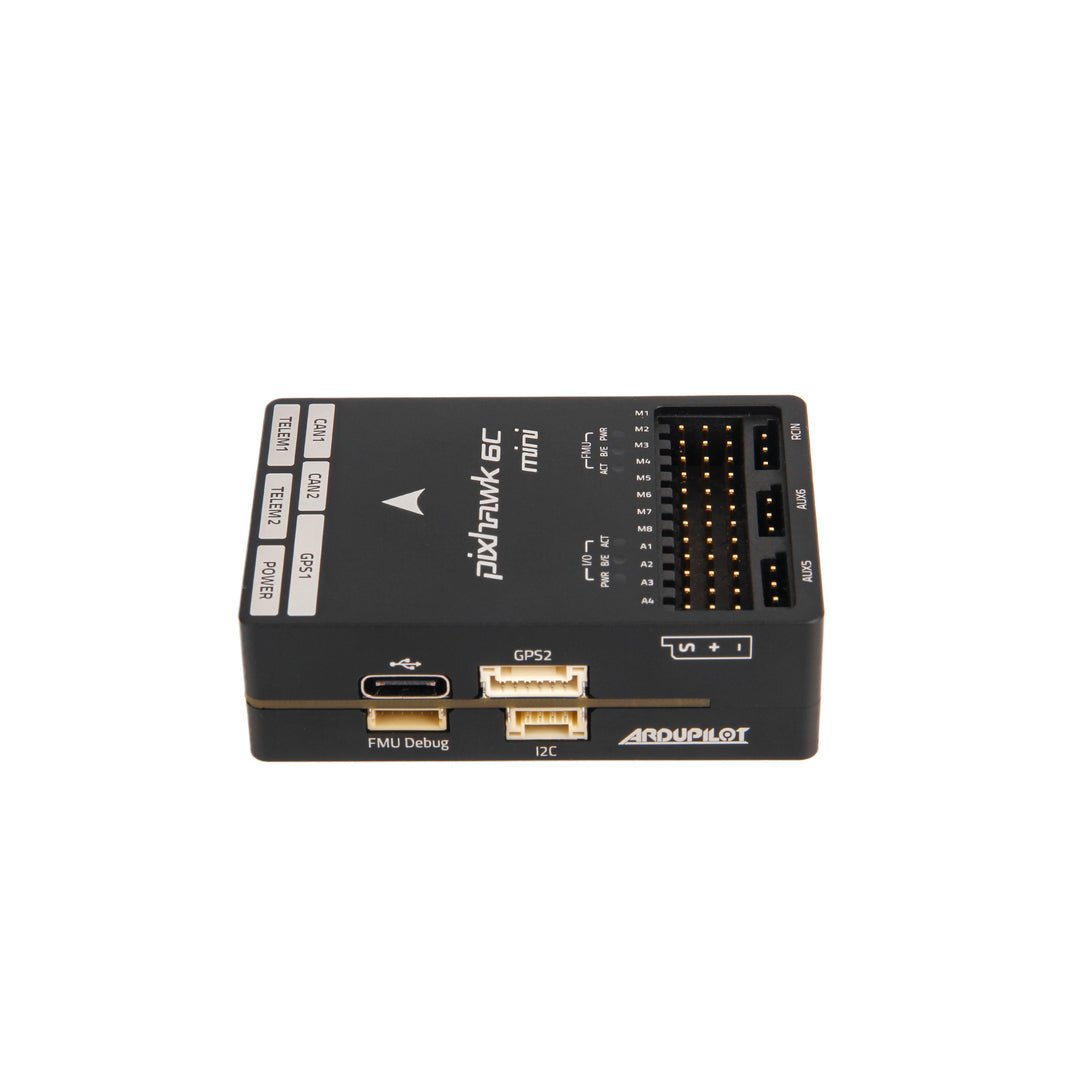
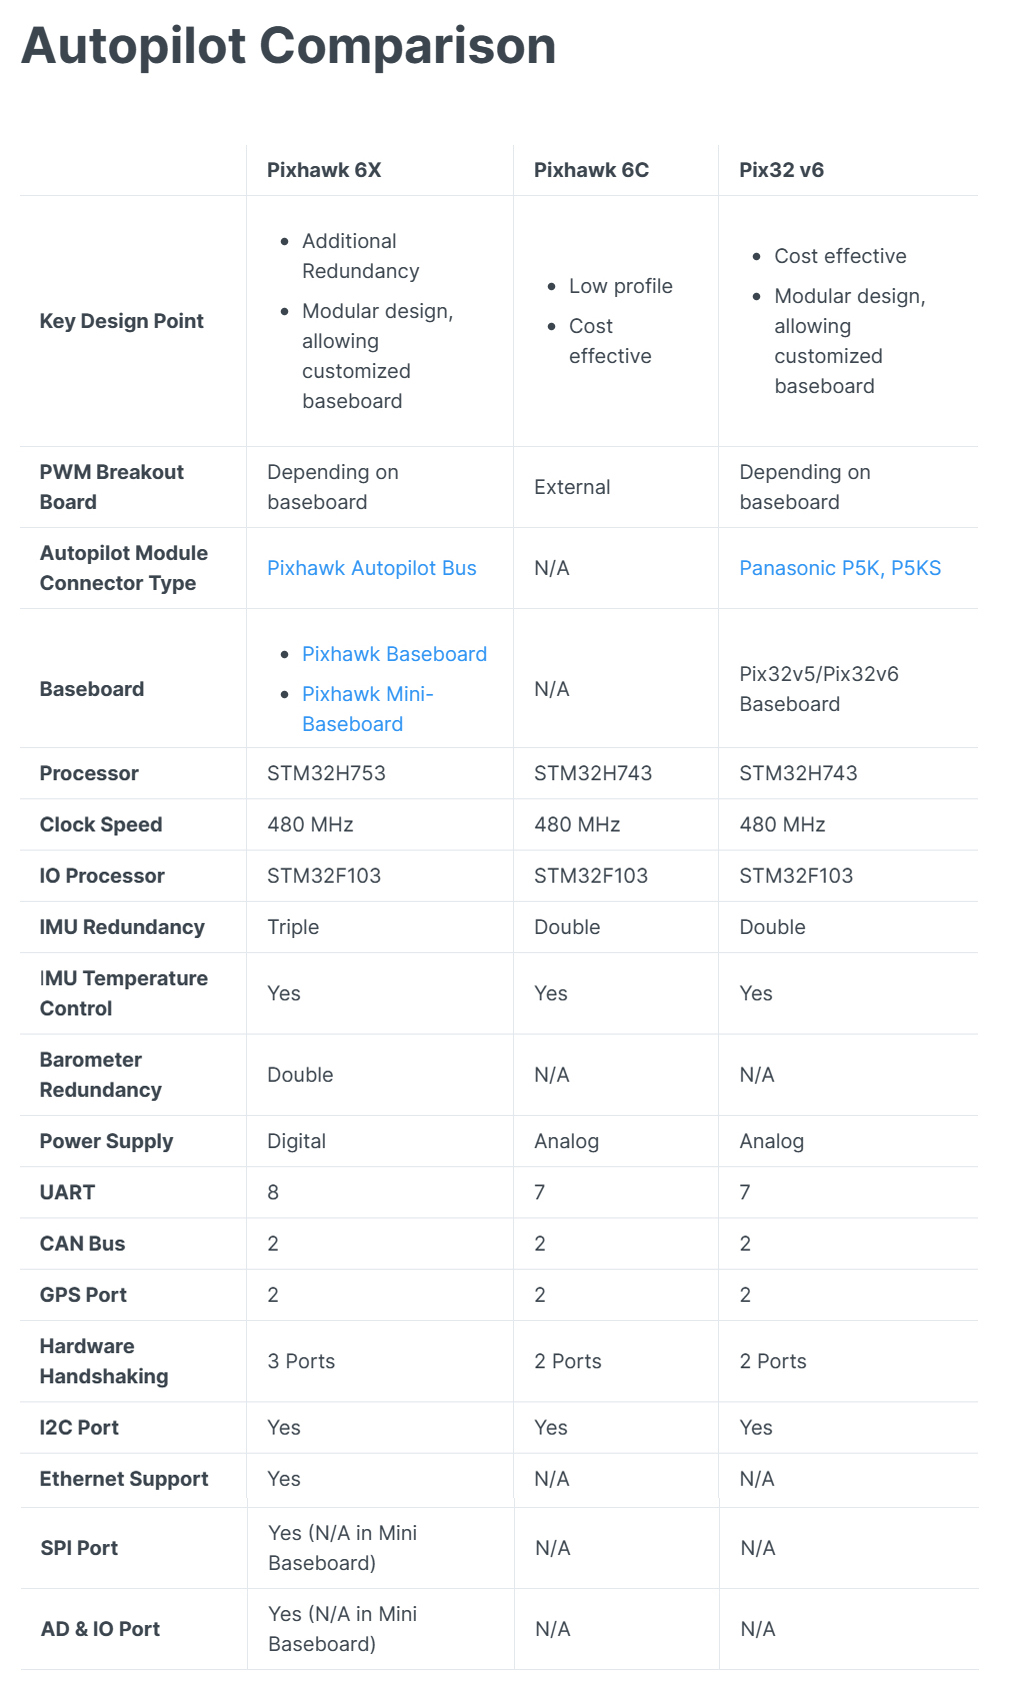
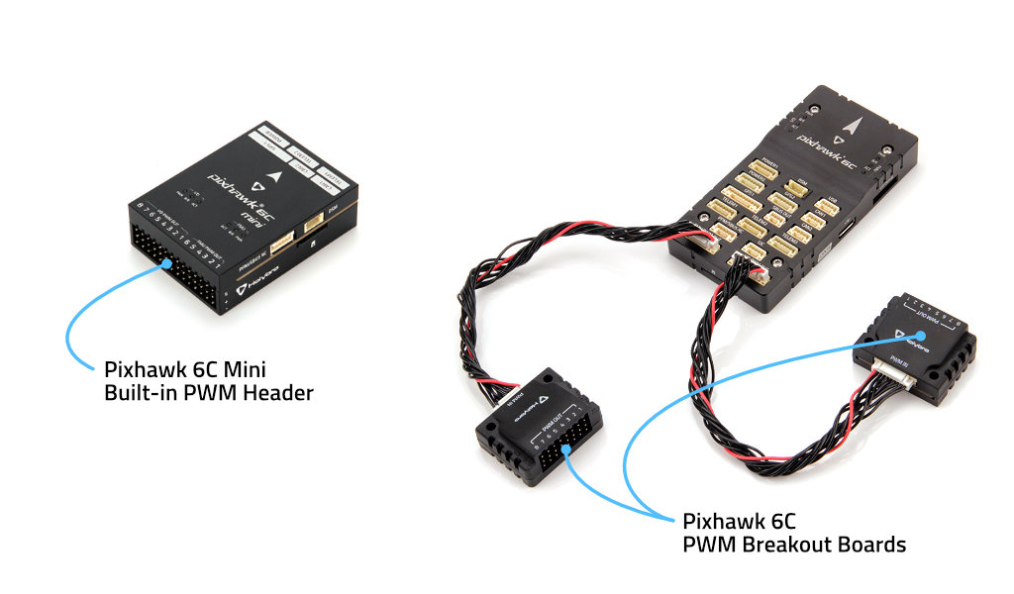
14- PWM servo outputs (8 from IO, 6 from FMU)
2 general purpose serial ports
Telem1 - Full flow control, separate 1.5A current limit
Telem2 - Full flow control
2 GPS ports
GPS1 - Full GPS port (GPS plus safety switch)
Basic GPS port
1 I2C port
Supports dedicated I2C calibration EEPROM located on sensor module
2 CAN Buses
FMU Debug (Pixhawk Debug Mini)
Dedicated R/C input for Spektrum/DSM and S.BUS, CPPM, analog / PWM RSSI
1 Power input port (Analog)
Other Characteristics
Operating temperature
-40 ~ 85°c
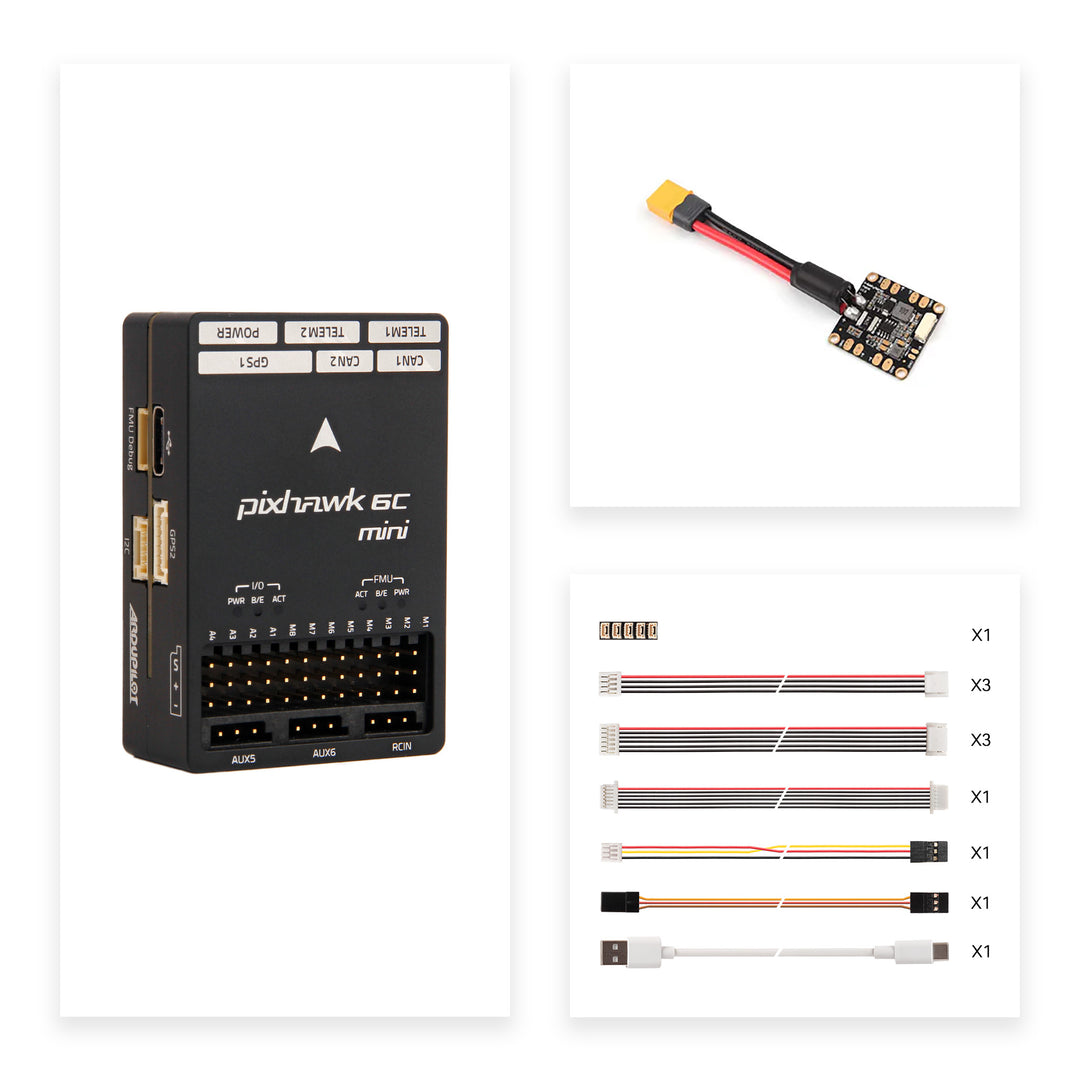
제품 구성품 2 : [Holybro] 픽스호크 PM06 V2 전원 모듈 - (최대 14S 업그레이드 사양)
설명:
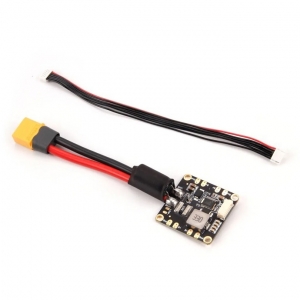
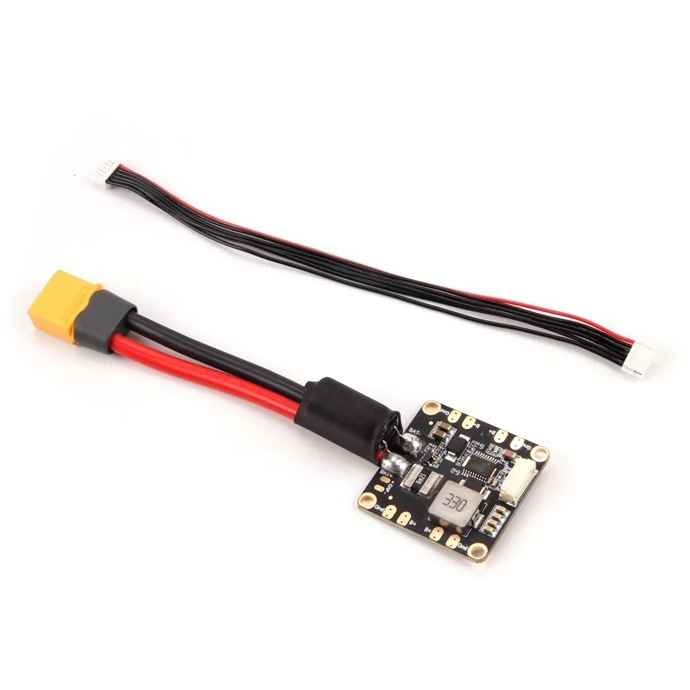
이 PM06 전원 모듈은 배터리에서 비행 컨트롤러로 깨끗한 5.2V를 공급하고 6핀 JST-GH 케이블을 통한 아날로그 신호를 통해 전류 소비 및 배터리 전압 측정을 제공하며 4개의 ESC에 대한 통합 전력 분배도 제공합니다. 사전 납땜된 전선, 커패시터 및 XT60 커넥터가 함께 제공됩니다.
명세서:
입력 전압(14S 버전): 2S-14S
PCB Cont. 전류 정격: 70A
PCB 버스트 전류 정격: 120A(<60초)
출력: DC 5.2V & 3A 최대
출력 최대 전력 : 18W
전압 분배기: 18.182
볼트당 암페어: 36.364
참고사항:
보드에 미리 납땜된 XT60 플러그와 12AWG 와이어는 30A 연속 전류와 60A 버스트 전류(< 60초)에 대한 정격입니다. 더 높은 전류를 사용하는 경우 플러그 유형과 와이어 크기를 그에 따라 변경해야 합니다. 참조할 수 있습니다. 이 차트 참고로.
이 PM02 전력 모듈은 아날로그 데이터 출력을 사용하며 Pixhawk 5X 및 6X와 호환되지 않습니다(PM02D와 같은 디지털 PM이 필요함).